Don’t just read
what a tool can do.
See it. Then try it.
30 interactive 3D exhibits.
Understand the method, change the inputs, and call the real MCP tool.
A little curiosity goes a long way.
30 demonstrations · interactive 3D, methods explained, assumptions included
 POINT-CLOUD PROFILE / RUST CPU01
tour_profileRead the geometry before choosing a method.
Compare a square, a line and two separated clusters. Inspect the supplied positions, then ask Rust for the distance distribution, isolation and directional spread.
Understand and try BOUNDED COUNTEREXAMPLES / RUST CPU02
scan_counterexampleFind the point that breaks a claim.
Declare a comparison, choose a discrete grid and look for a witness. See which cells were visited, where a violation was returned and why silence is never a proof.
Understand and try INVERSE ACOUSTICS / RUST CPU03
shape_the_soundGive a sound its shape.
Choose a chord and ask Rust to design a polygonal membrane. Inspect the returned shape, animate its computed vibration modes and compare requested and obtained tones.
Understand and try KEPLER SENSITIVITY / RUST CPU04
kepler_stabilityA small change. A different orbit?
Explore how nearby orbits separate in an ideal Sun–Jupiter system. Turn a grid of starting conditions into a sensitivity map, then inspect what each calculation actually established.
Understand and try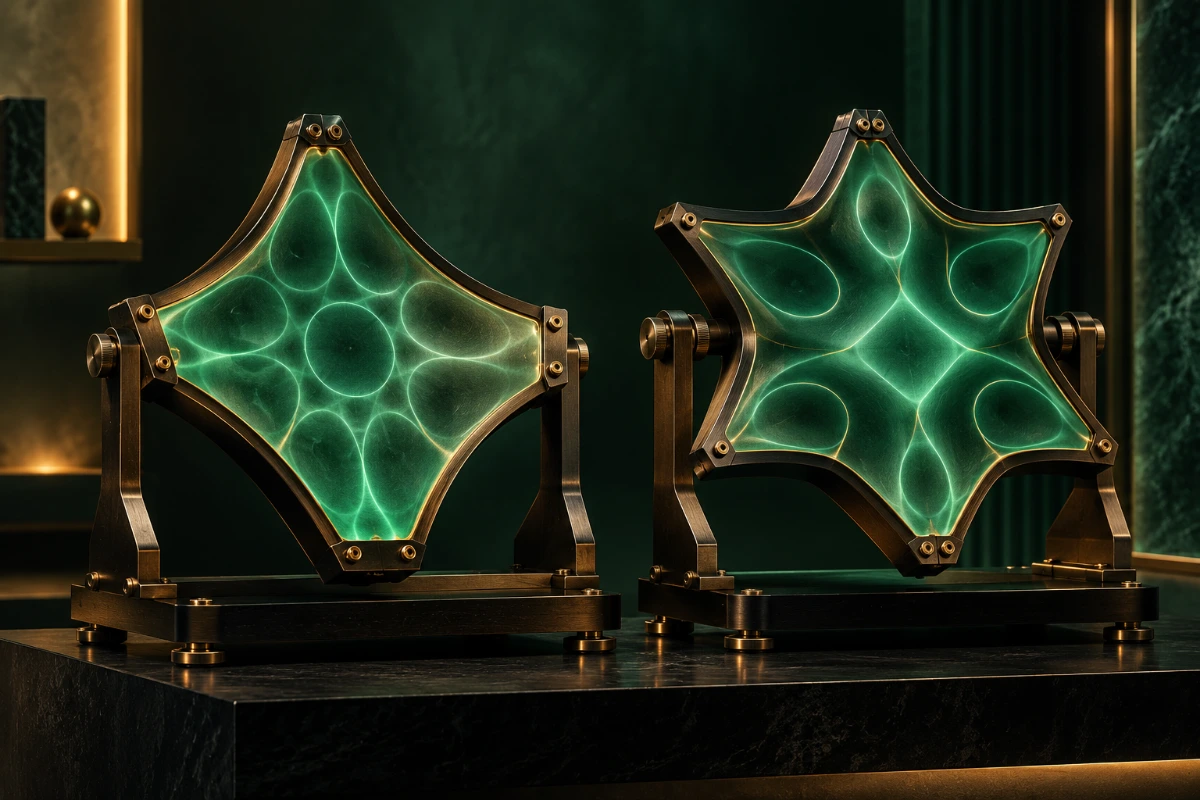 VIBRATING MEMBRANES / RUST CPU05
hear_the_shapeDifferent shapes. The same notes?
Compare two drum shapes, see their calculated vibration modes and listen to individual frequencies. Explore what a finite spectrum can — and cannot — tell you about a shape.
Understand and try MEASUREMENT UNCERTAINTY / RUST CPU06
propagate_uncertaintyHow certain is your answer?
Follow uncertain inputs through a formula. Compare first-order propagation with seeded Monte Carlo, see which inputs contribute most, and catch incompatible units before calculating.
Understand and try GOLDEN & BLUE HOUR / RUST CPU07
plan_golden_hourFind the light before you go.
Choose a date and location. Calculate the golden and blue light windows in one UTC day, including high-latitude cases where familiar sunrise patterns disappear.
Understand and try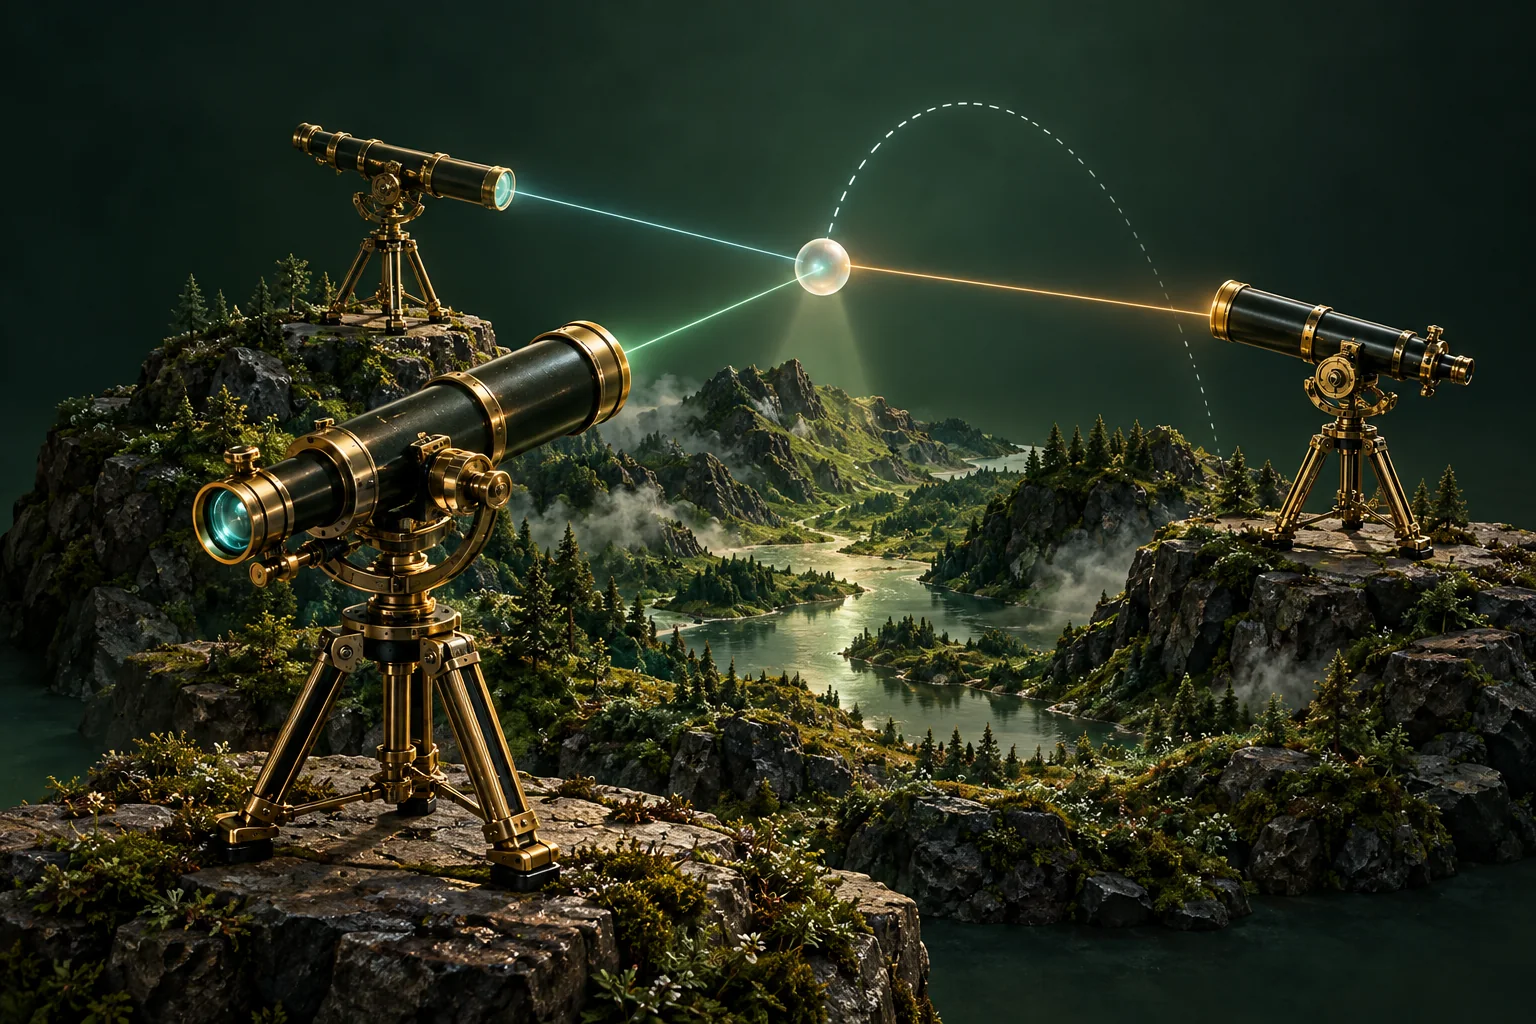 MULTI-OBSERVER TRACKS / RUST CPU08
triangulate_tracksWhere do the sightlines meet?
Combine timed angular observations from different locations to estimate a moving object’s 3D position and velocity, with residuals and explicit uncertainty limits.
Understand and try MONTE CARLO / CPU + CUDA09
simulate_piFind π in a cloud of points.
Turn a seeded cloud of random points into an estimate of π, with a convergence curve and sampling uncertainty you can inspect.
Understand and try EXACT SELECTION / INTEGER MINUTES10
optimize_tasksMake every minute count.
Give independent tasks a duration and a value. Rust selects the highest-value combination that fits the stated time budget.
Understand and try SCHEDULE RISK / DECLARED UNCERTAINTY11
simulate_planWhat happens when tasks run late?
Run a supplied plan through seeded duration variations and see how often it meets the deadline under that chosen model.
Understand and try GEOMETRIC TOURS / RUST CPU12
route_optimizerFind a shorter way around.
Connect supplied points into a complete tour, then inspect every leg, the search method and whether optimality was actually established.
Understand and try KEPLER / TWO-BODY MODEL13
compute_orbitFollow an ellipse through time.
Change the shape and elapsed time of an ideal orbit, then inspect its trajectory, position and orbital period.
Understand and try SOLAR GEOMETRY / IMAGE MEASUREMENTS14
verify_shadowsDoes the shadow fit the Sun?
Compare a measured shadow with a calculated solar direction after mapping image pixels onto a declared ground plane.
Understand and try SUN + MOON / POSITION CONSISTENCY15
check_ephemerisPut a sky claim in context.
Compare a claimed Sun or Moon position with an approximate ephemeris at a supplied place and UTC time.
Understand and try GRIM + GRIMMER / INTEGER ARITHMETIC16
audit_statisticsCan that rounded mean exist?
Ask whether a reported mean or standard deviation passes necessary arithmetic checks for bounded integer observations.
Understand and try ANGULAR MOTION / EXPLICIT HYPOTHESES17
analyze_kinematicsDistance changes the speed story.
Convert observed angular motion into transverse speed at chosen distances and inspect the consequences of a claimed speed-distance pair.
Understand and try TEMPORAL CONSISTENCY / MEASURED TRACKS18
check_shadow_trackRead time in a moving shadow.
Compare supplied shadow angles over time with expected solar motion, including individual residuals and the direction of rotation.
Understand and try KUHN POKER / CFR+ SELF-PLAY19
solve_equilibriumWatch a tiny game find balance.
Explore a three-card imperfect-information game with regret-based self-play, a strategy table and explicit exploitability measurements.
Understand and try STOCKFISH / MOVE-QUALITY PROFILE20
analyze_chess_gameCompare moves without accusing players.
Ask Stockfish to assess supplied positions and compare the played moves with its bounded-depth recommendations.
Understand and try TRADE SERIES / DESCRIPTIVE SCREENING21
screen_wash_tradingInspect a repeating market pattern.
Examine a synthetic series for repeated volume at nearly identical prices, with a declared time window and price band.
Understand and try DISCOVERY / NATIVE TOOL LIBRARY22
list_capabilitiesRead the engines’ contracts.
Inspect the thirteen registered composition-bank tool contracts, their themes, units, backends, assumptions and current readiness.
Understand and try MISSION PREVIEW / NO ENGINE EXECUTION23
plan_missionPreview the work before it runs.
Validate a robust-scheduling request and inspect its bounded candidate budgets, required tools and maximum work.
Understand and try ROBUST SCHEDULING / THREE CANDIDATES24
build_robust_planChoose value with room for uncertainty.
Compare a bounded family of task selections, preserving their values while checking whether a declared success target is supported.
Understand and try CAPABILITY BANK / CONTRACTS + ADAPTERS25
list_composition_capabilitiesExplore the bank of typed capabilities.
Read the implemented engines, two explicit duration adapters and one scheduling composite alongside their versioned input and output facts.
Understand and try TYPED PLANNING / BOUNDED SEARCH26
compose_capabilitiesLet Rust assemble an admissible path.
Start from available contracts and a desired result. Rust searches registered dependency paths while enforcing permissions and explicit limits.
Understand and try NATIVE COMPOSITION / TWO ENGINES + ONE ADAPTER27
execute_compositionA route becomes a checked risk study.
Execute an approved route-to-risk chain with checked identities, explicit units, caller-supplied speed and real native progress events.
Understand and try CONTRIBUTOR POOL / LIVE OBSERVATION28
network_statusSee the pool that is actually offered.
Read the contributor network’s fresh resource offers, busy GPUs and observed verified throughput without submitting a calculation.
Understand and try PUBLIC JOB / FIXED INTEGER MONTE CARLO29
submit_network_jobSend a small experiment to the pool.
Queue a synthetic π experiment, receive a real ticket and follow counts that the coordinator verifies before aggregation.
Understand and try JOB PROGRESS / CHECKED RESULTS30
get_network_jobFollow a real ticket to its receipt.
Supply a job_id returned by submit_network_job to inspect verified progress, completion or expiry for that public experiment.
Understand and try